See through the camera you will deploy
Simulators render through a perfect pinhole; robots see through real lenses. TwinRobo renders simulated scenes through the actual optics of off-the-shelf cameras, so perception trained in simulation meets the same image on the robot. See why TwinRobo?
Try it live Get started Browse cameras
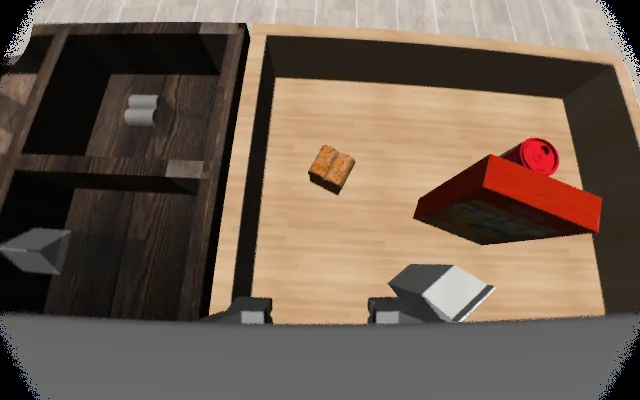
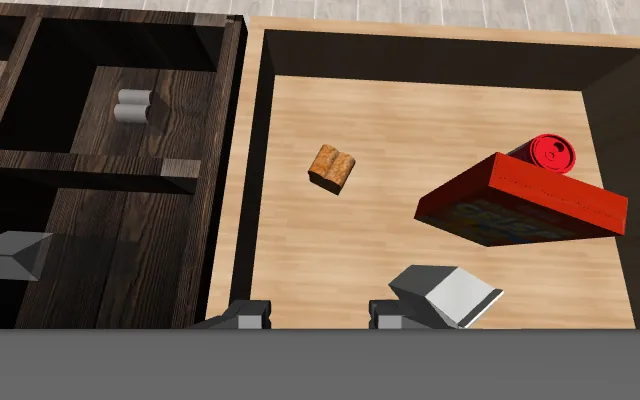 Pinhole
Real camera
Drag to compare: a robot's wrist camera in MuJoCo, the same frame, pose and field of view, through the simulator's pinhole and through a real camera's lens.
Change the camera, and a robot policy drops from 85 % to 0 %
OpenVLA solves 85 % of its LIBERO tasks through the pinhole camera it was trained with, and none through a real camera placed where that pinhole was. TwinRobo shows you that before your robot does. See the benchmark
OpenVLA on the same LIBERO task from the same start, seen through its own (third-person) camera: through the simulator's pinhole it succeeds (left); through a real camera at the same place it fails (right).
One environment, any real camera
-
Real lens optics
Lenses traced with DeepLens: depth- and field-dependent blur, the lens' own distortion, chromatic aberration and vignetting, from a prescription, not a hand-tuned filter.
-
Two rendering methods
A fast 2.5D PSF renderer, plus a ray caster that traces every pixel's rays through the lens into the scene, exact even around defocused foreground objects.
-
Drop-in for simulators
MuJoCo, LIBERO, RoboCasa and NVIDIA Isaac Sim. Wrap a camera and policies, eval scripts and recorded demos run unchanged, now through a real camera.
-
An open camera catalog
RealSense, ZED, OAK-D, a C920 webcam and the Raspberry Pi camera, as single cameras or rectified stereo pairs. Every camera works in every simulator and method, and a real unit can be calibrated.
Support at a glance
| MuJoCo (incl. LIBERO, RoboCasa) | NVIDIA Isaac Sim 6.x | |
|---|---|---|
| Adapter | MujocoCameraTwin |
IsaacCameraTwin |
psf: pinhole + lens blur and distortion |
||
raycast: lens rays cast into the scene |
||
| RGB on the GPU, ground-truth depth on request | ||
| Cameras on robot links, stereo modules | any USD camera prim | |
| Setup | pip install |
Docker recipe included |
Five lines to a real camera
from twinrobo import CameraTwin
from twinrobo.datasets.libero import CameraTwinLiberoEnv, make_env

env, task, init_states = make_env("libero_spatial", 0, resolution=128)
env = CameraTwinLiberoEnv(env, {"agentview": CameraTwin.from_catalog("stereolabs/zed-x/4mm")})
obs = env.reset()                # obs["agentview_image"] now comes from the twin
Validated in both simulators
-
46 dB
PSF renderer vs DeepLens' reference renderer at 1920×1200.
-
< 0.1 px
Points land where the lens' chief rays point (Isaac Sim).
-
~0.03 vs ~0.13
Error on a defocused foreground edge: ray cast vs pinhole + PSF (Isaac Sim; MuJoCo ~0.05).
Your camera is missing? Add it
The catalog is the heart of TwinRobo, and it is open. A camera is a
camera.yaml and a lens file; once merged it works in every simulator,
rendering method and dataset replay, for everyone.
Camera makers: become a partner
Robot teams now choose and validate cameras in simulation. Ship
manufacturer_verified models of your products, get listed as a partner and
showcased, or sponsor the open environment your customers use.